91视频69-91视频91-91视频91九色-91视频91自-91视频97-91视频9999-91视频99视频-91视频av-91视频cn-91视频com

JS Game M1

A hardware of multi-sensor fusion architecture and microsecond time synchronization mechanism specially provided for developers

JS Game M1

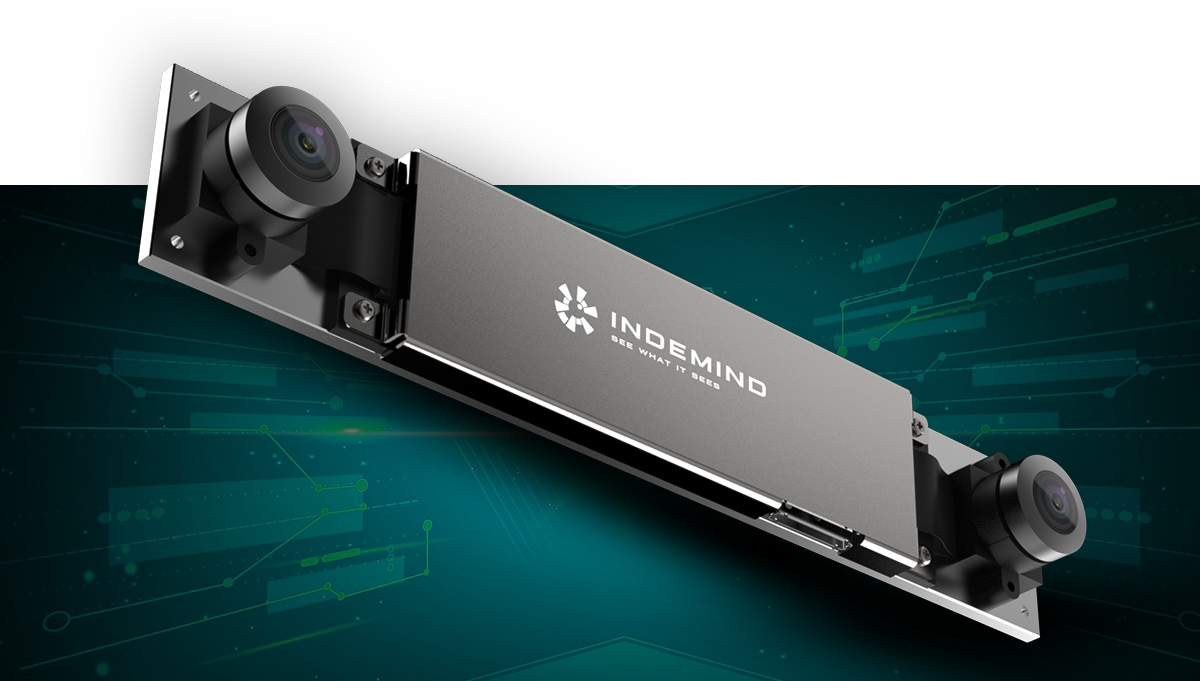
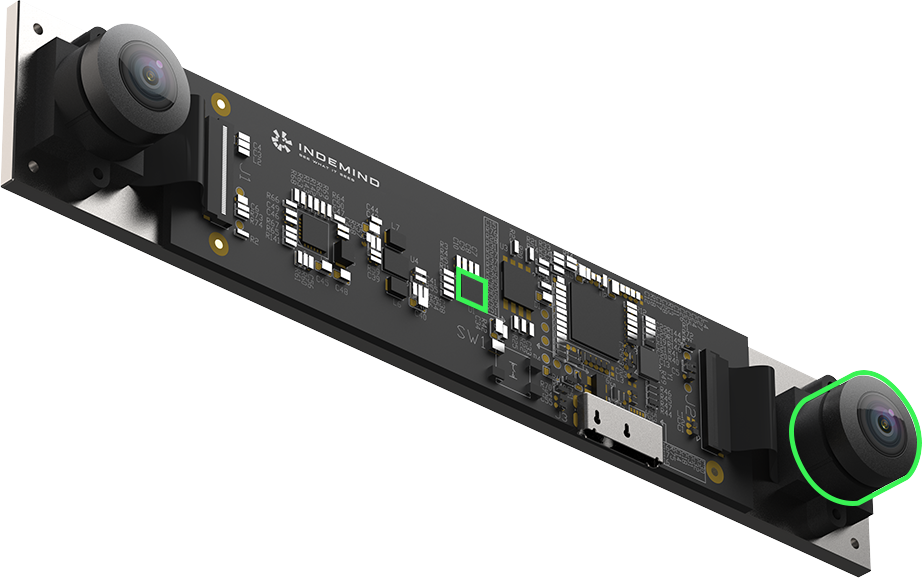
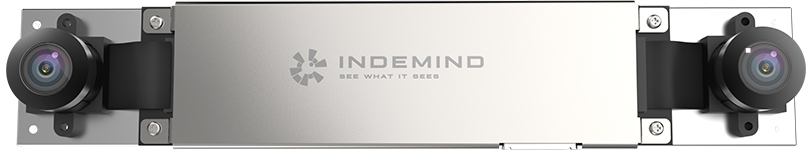
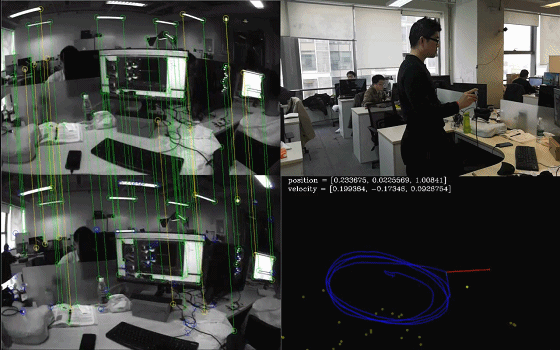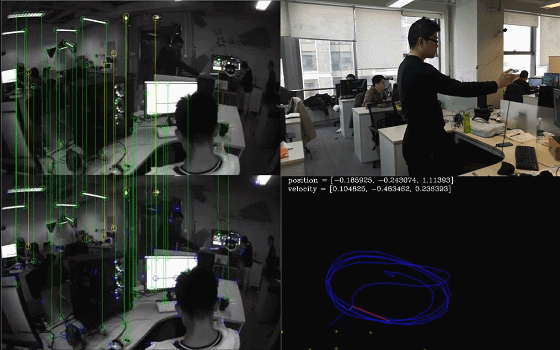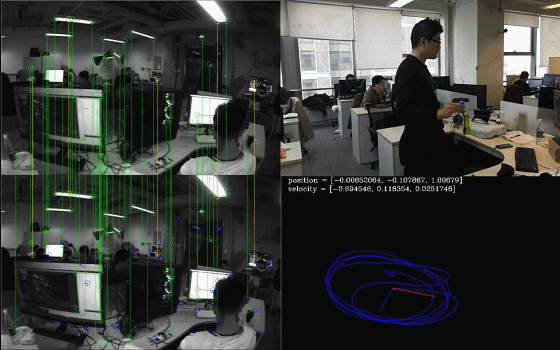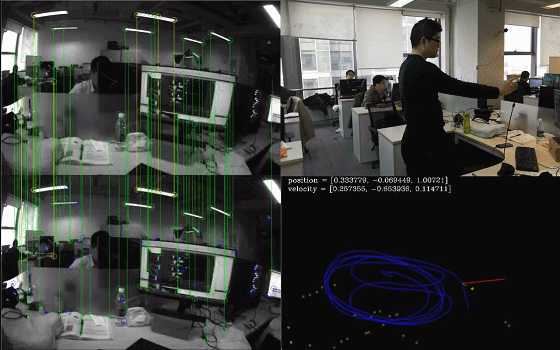
JS Game M1, a hardware for developers, adopts a "binocular camera + IMU" multi-sensor fusion architecture and microsecond time synchronization mechanism, to provide accurate and stable data sources for visual SLAM research, to meet the development requirement such as SLAM research, navigation and obstacle avoidance development, visual motion capture development, stereo vision development and others.

JS Game  M1

200FPS high-speed data acquisition

JS Game Binocular Inertial Module is the first binocular inertial camera that supports 200FPS image acquisition. It can accurately obtain the image and IMU data under high-speed maneuverability, accommodate high-speed acquisition demands of developers, greatly decrease the tracking difficulty of the related algorithm, and accommodate positioning and mapping data demands of the high-speed SLAM algorithm (e.g. vehicle-mounted).

Binocular camera +IMU

With the camera +IMU multi-sensor fusion structure, the module can realize compensation between the camera and IMU sensor and provide a solution for binocular stereoscopic visual hardware with higher attitude accuracy, stronger environmental suitability, more stable dynamic performance, and lower costs.

High-resolution camera

The high-definition camera with a global shutter can provide 1280×800@25/50/100FPS & 640×400@25/50/100/200FPS image data in the range of horizontal 120° and vertical 75° level, and effectively reduce image distortion detected under motion image to provide strong front-end data acquisition capacity for SLAM algorithm.

Built-in 6-axis IMU sensor

The built-in 6-axis IMU sensor with max. operation frequency 1000Hz can accurately measure motion characteristics of the carrier, refresh attitude information of the carrier in high frequency, and fast create a 3D perception for surroundings.

Binocular +IMU microsecond-level synchronization

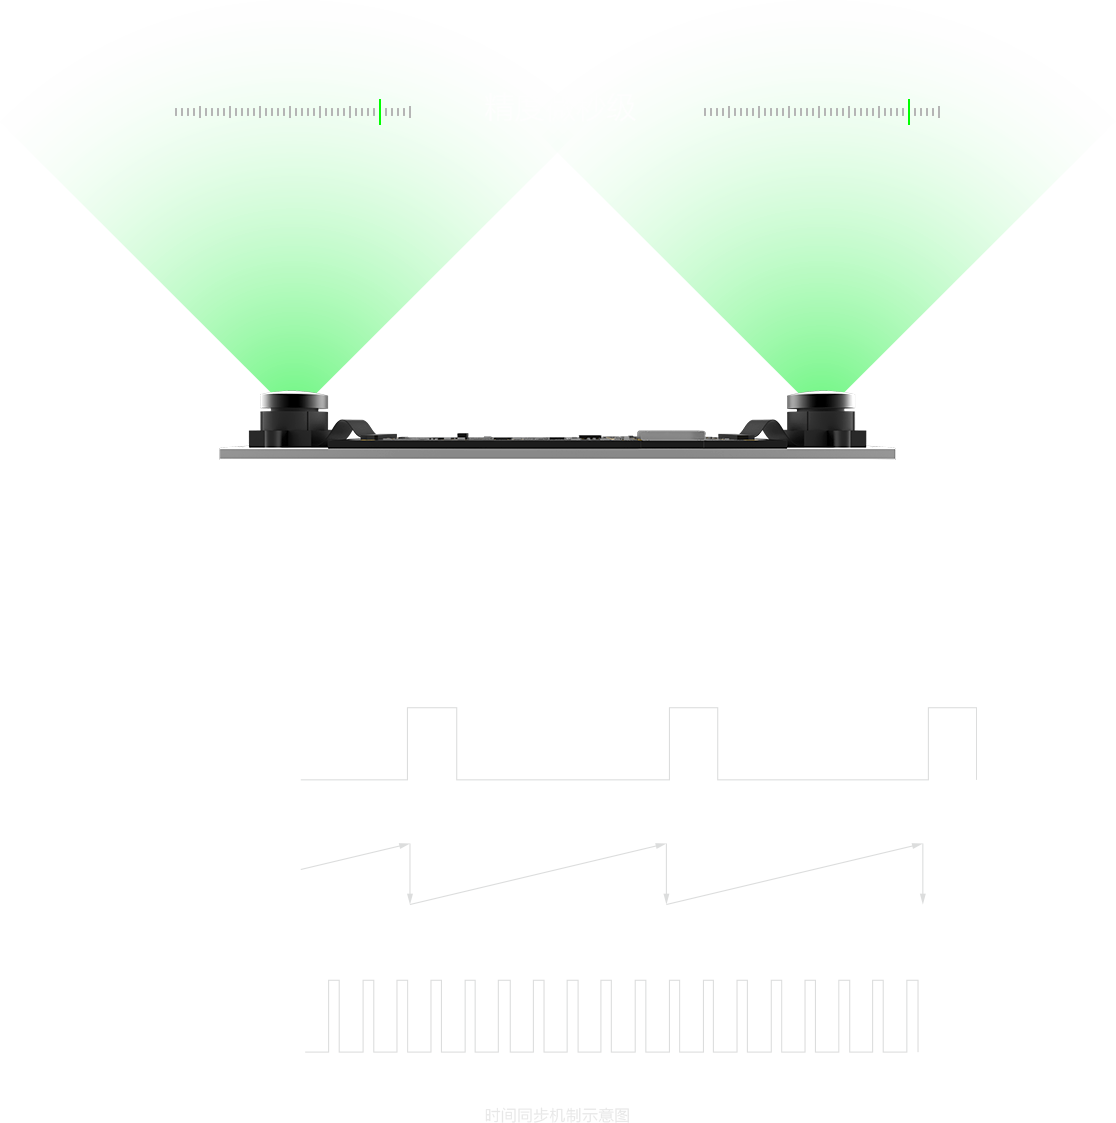
The unique high-precision time synchronization mechanism can improve the synchronization accuracy between the binocular camera and IMU to a microsecond level and reduce sensor error to further provide an accurate and stable data source for the SLAM algorithm.

Multi-sensor calibration

The professional calibration is made for multiple sensors such as camera and IMU, of which accuracy is superior to other open-source calibration methods (e.g. Kalibr) to reduce multi-sensor assembly error and further improve the accuracy of data acquisition and system stability.

Kalibr:

組別 head(°) pitch(°) roll(°)
1 -179.5008 -0.6017 0.6507
2 -179.3397 -0.6017 0.6507
3 -179.1031 -0.1903 0.4534
STD 0.2000 0.2211 0.1502

JS Game:

組別 head(°) pitch(°) roll(°)
1 -179.521225 -0.439943 0.622170
2 -179.602241 -0.463838 0.598827
3 -179.780491 -0.662679 0.404572
STD 0.1326 0.1223 0.1195
The experimental results show that the repeatability accuracy of JS Game calibration installation angle error is 1.5 times that of Kalibr algorithm, and the camera re projection error is also better than that of Kalibr algorithm.

SDK

Data acquisition
The binocular +IMU structure and USB3.0 transmission characteristics can realize high-speed and stable data acquisition.
Object detection
Based on the deep learning technology, the product can realize semantic, size, and attitude information recognition and detection for environmental objects.
Depth map
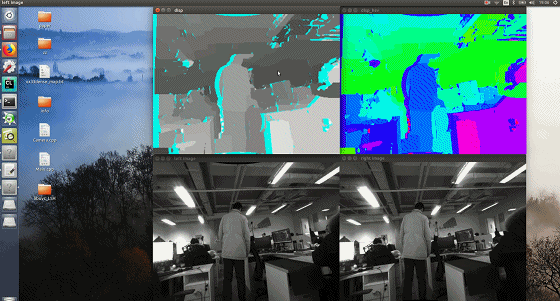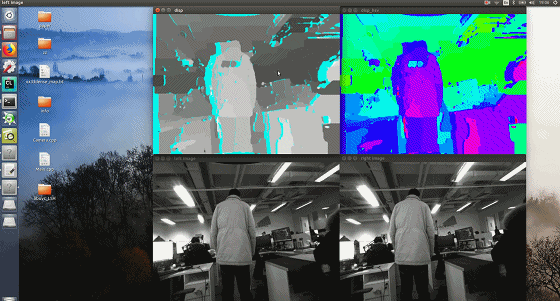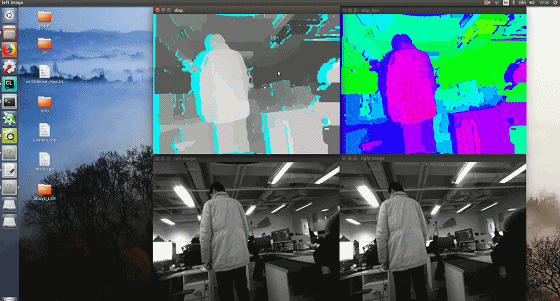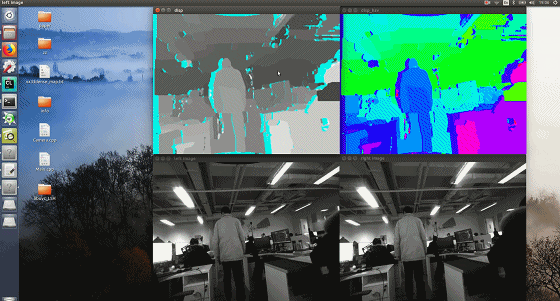
The collected depth map can be used for obtaining depth information of objects. Besides, the open-source algorithm can be used for obtaining 3D data of objects.
Point cloud
The dense point cloud map can be created to generate the 3D model of objects.

Hardware technical indicators

  • Applicable distance:

    0.1m-10m

  • Lens:

    Replacable Standard M12

  • Visual angle:

    D:140° H:120° V:75°

  • Resolution:

    1280×800 | 640×400

  • FPS (frames per second):

    25FPS | 50FPS | 100FPS | 200FPS

  • Baseline:

    120mm

  • IMU frequency:

    1000Hz

Developer Support

  • Visual frequency:

    25Hz

  • IMU frequency:

    200Hz

  • Applicable OS:

    Windows、Linux、ROS

  • Calibration file:

    IMU calibration, camera calibration, IMU/camera’s external parameters calibration

  • Developer support:

    SDK

Field of application

Visual SLAM research

Visual SLAM research

The binocular visual-inertial module uses the global shutter camera and 6-axis IMU to realize time synchronization between camera and IMU and reach the microsecond level for accuracy of time synchronization. Besides, the module provides IMU calibration parameters, camera calibration parameters, and external parameters of camera and IMU for high-accuracy SLAM development.

Visual motion capture and development

Visual motion capture and development

Based on the module image data, the product uses the human kinetics algorithm to realize 3D stable and high-precision multi-user skeleton tracking.

Navigation and obstacle avoidance development

Navigation and obstacle avoidance development

The binocular visual-inertial module can be compatible with multiple open-source projects and can provide various map modes (e.g. dense map, point cloud map) to lay an essential foundation for navigation and obstacle avoidance development. It can be widely used for developing wearable devices, UAVs, robots, and AGVs.

Stereoscopic vision development

Stereoscopic vision development

The Binocular Visual Inertial Module adapts to a number of open-source algorithms and enables ultra-high precision recognition and detection over a fixed range, thereby providing users with high-accuracy 3D point coordinates for high-precision scene reconstruction.

Product name: Binocular visual-inertial module

Product specification

  • Product

    Product name: Binocular visual-inertial module

  • Size

    PCBA plate: 95mmx25mm; Overall length and width: 140mmx25mm

  • FPS (frames per second)

    【25FPS】【50FPS】【100FPS】【200FPS】

  • Resolution

    【1280×800】【640×400】

  • Depth resolution

    Based on CPU Up to 640×400@25FPSz

  • Pixel size

    3.0 x 3.0μm(1280×800)

  • Shutter speed

    5ms

  • Baseline

    120.0 mm

  • Lens

    Replacable Standard M12

  • Visual angle

    D:140° H:120° V:75°

  • Focal length

    2.09mm

  • Filter

    N/A

  • Motion perception

    6 Axis IMU

  • Color pattern

    Monochrome

  • Scanning mode

    Global shutter

  • Power consumption

    1.05W @ 5V DC from USB

  • Synchronization precision

    Microsecond level

  • IMU frequency

    1000Hz

  • Output data format

    Raw data

  • Interface

    USB 3.0

  • Weight

    40g

  • UVC MODE

    YES

  • Applicable distance

    0.1-10m

Software

  • Applicable OS:

    Windows10、Linux、ROS

  • Developer support:

    SDK development and document

  • Calibration file:

    IMU calibration, camera calibration, IMU/camera’s external parameters calibration

  • Hardware requirements:

    CPU、USB3.0

Environment

  • Operating temperature:

    -10°C~60°C

  • Storage temperature:

    -40°C~120°C

  • Humidity:

    0% to 90% NON-CONDENSING

Packaging

Packaging:

Packaging: 1× binocular visual-inertial module; 1× Micro USB 3.0 USB cable; User Manual; portable bag

Warranty

Warranty

If the binocular visual-inertial module occurs any hardware fault due to non-deliberate damage within one year as of the date of purchase, after detection by the after-sales service center, JS Game will provide free warranty service.

FAQ

E-mail:support@www.JSGame.com

Which kind of task and scenario are applicable to the binocular visual-inertial module?

With computer vision technology, the JS Game binocular visual-inertial module can provide a stable and reliable hardware foundation. Besides, the module can use the computer vision algorithm to accommodate SLAM, deep calculation, object recognition, gesture recognition, face recognition, dense mapping, and obstacle detection under the field of SLAM research, robot, UAM, AR/VR, and AGV.

Will the module support the open-source SLAM project?

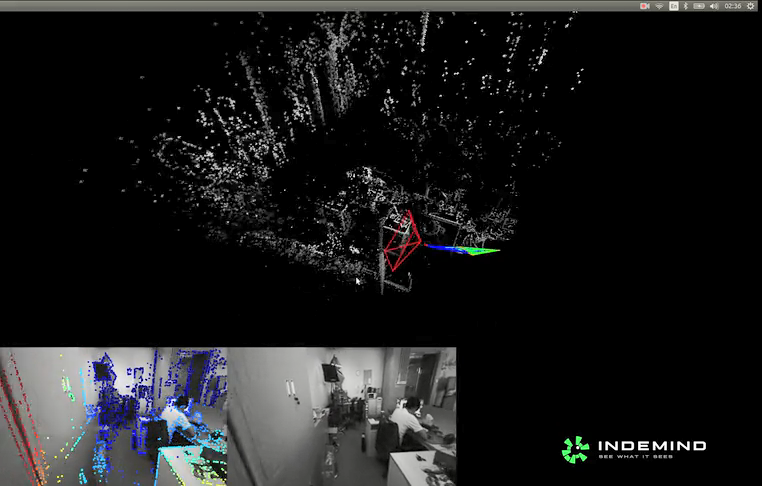
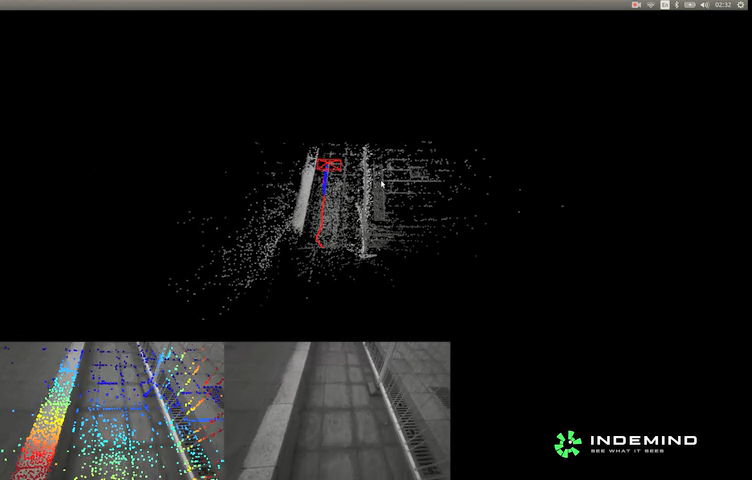
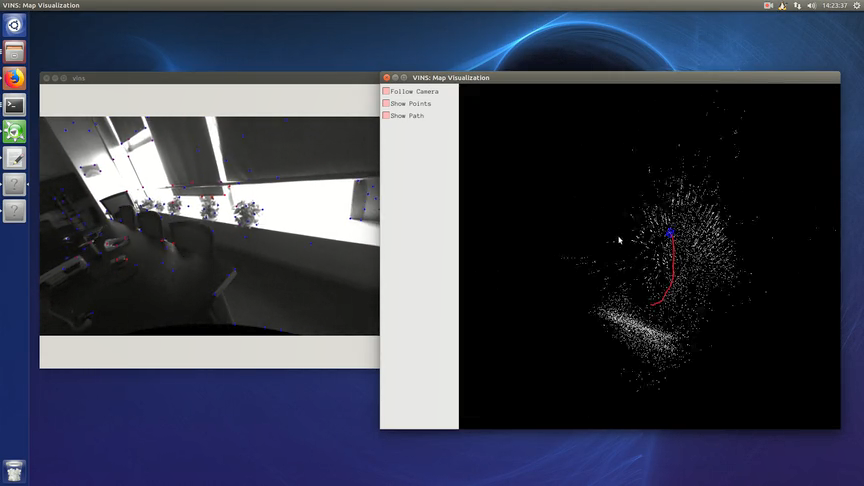
JS Game binocular visual-inertial module data support common open-source SLAM projects (e.g. ORB SLAM, VINS, DSO, SVO) and support users to create the test set similar to the EuRoc format.

Which kind of data output will SDK support?

Through applicable client software or SDK, the module can support binocular image, IMU data output and storage.

What is the effect of object recognition?

It will recognize an object and measure the position information of the object under the world coordinate system and obtain the 3D semantic map.

Will the module SDK be used for a developing environment?

SDK supports Windows & Linux system environments.

Will the camera realize hardware synchronization with the IMU sensor?

Yes. The built-in high-precision chip can control time synchronization between the binocular camera and IMU sensor to realize accuracy up to a microsecond level.

Will JS Game binocular visual-inertial module be calibrated before delivery?

Yes. Before delivery of JS Game binocular visual-inertial module, we will make professional calibration for external parameters of camera-IMU (including installation angle, lever arm), camera, and IMU to ensure availability of module.

INDMEIND雙目視覺慣性模組支持運行多種開源算法,實現(xiàn)高精度定位效果(自研VSLAM暫不對外)

完整視頻

JS Game雙目視覺慣性模組支持輸出高精度深度圖像

完整視頻

開源算法示例

ORB運行演示

DSO運行演示(室內(nèi)環(huán)境)

DSO運行演示(室外環(huán)境)

VINS運行演示

技術支持

任何產(chǎn)品相關的技術問題均可和在線客服進行交流,我們將盡快為您提供幫助

  • QQ customer service

    3457489099

  • WeChat Assistant

    WeChat search:JS Game

  • Technical service E-mail

    support@www.JSGame.com

主站蜘蛛池模板: 伦理在线免费 | 91麻豆福利社 | 日日骚欧美| 福利精品第一导航 | 日本a级在线 | 欧美亚洲视频一区 | 欧美情色片 | 91桌面| 精品一二二四五区 | 成人三级片网站 | 岛国七区在线播放 | 性欧美vr| 国产97在线亚洲 | 国产视频青青 | 狠狠撸人人肏 | 少妇精品 | 欧美伦理影院 | 日韩免费视频观看 | 福利精品在线 | 久久东京 | 超碰福利香蕉 | 三级黄色Av视屏 | 国产漫头B一线天 | 欧美成人手机版 | 国产视频免费观看 | 成人性无码 | 91超碰碰碰 | 久草视频资源网 | 91在线网站 | 毛片观看网址 | 国产日韩欧美在线 | 欧美日韩综合网 | 欧美自慰六区 | 91手机福利 | 免费观看黄色 | 曰本黄色三级网站 | 深夜福利99 | 亚洲色图欧美力累 | 爱豆传媒网站 | 欧美另类色 | 亚洲精品一区二区 |